Overview
SmartManipulator-X is a robot arm project. It combines the ROS 2 control and operator-software concepts of ROBOTIS OpenMANIPULATOR-X with the mechanical design of BCN3D Moveo. A Microchip SmartFusion2 controller drives the stepper motors of the Moveo joints and a hobby servo on the gripper, and presents them to the ROS 2 host as virtual DYNAMIXEL devices over Protocol 2.0.
This documentation covers the Operator PC: the computer on which the operator plans motions and watches the arm. The whole system — the Robot PC, the controller firmware, the hardware and the mechanics — is documented on the SmartManipulator-X system site, which is published from the Robot PC repository.
What the Operator PC does
| Owns | Does not own |
|---|---|
MoveIt 2 motion planning (move_group, OMPL, pick_ik) |
The USB link to the SmartFusion2 controller (/dev/ttyACM0) |
| RViz2 with the MotionPlanning panel | ros2_control, the controllers and the hardware interface |
| The semantic robot description (SRDF), kinematics, planning limits, controller mapping | The robot description (URDF/Xacro and meshes) — it is consumed from the Robot PC repository |
| Its Docker image, Compose services and GUI setup | The motor drivers, the firmware, the power and the emergency stop |
| Simulation workflows (Gazebo: planned, not in this repository yet) |
The Operator PC never talks to the motor controllers. It plans in MoveIt and sends the
trajectories as FollowJointTrajectory actions over ROS 2 DDS to the Robot PC, which
runs ros2_control:
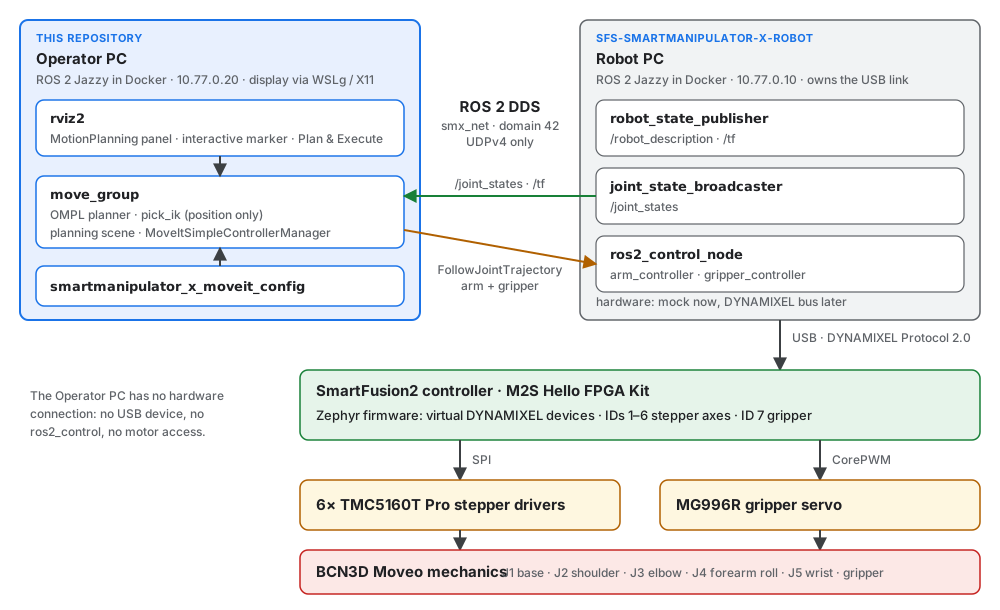
System components
| Component | Role | Platform |
|---|---|---|
| Operator PC (this repository) | Motion planning and visualization: MoveIt 2, RViz2; simulation later | ROS 2 Jazzy in Docker; DDS client of the Robot PC |
| Robot PC | Robot-side ROS 2 control: ros2_control, the ROBOTIS hardware interface and DynamixelSDK; owns the USB link to the controller |
Ubuntu 24.04, ROS 2 Jazzy in Docker |
| Controller firmware | DYNAMIXEL Protocol 2.0 device: six stepper axes (IDs 1–6), the gripper servo (ID 7) and a controller device (ID 200) | Zephyr RTOS on the SmartFusion2 Cortex-M3 |
| FPGA design | Pin routing of SPI and UART, CorePWM for the gripper servo | SmartFusion2 FPGA fabric |
| Drives | Six TMC5160 modules in motion-controller mode, MG996R gripper servo | 24 V and 6 V supplies |
| Mechanics | Joints, links and printed parts | BCN3D Moveo |
Repositories
| Repository | Content | Documentation |
|---|---|---|
| sfs-smartmanipulator-x-operator | This repository: Operator PC image, MoveIt 2 configuration, RViz2 setup, this documentation | This site; the system view in Operator PC |
| sfs-smartmanipulator-x-robot | Robot PC image and ROS 2 workspace, the robot description generated from the Moveo CAD, the Fast DDS profile, the system documentation | Robot PC, BCN3D Moveo mechanics |
| SmartManipulator-X-Controller | Zephyr firmware of the SmartFusion2 and the motor tester GUI | Firmware, Motor tester GUI |
| SmartManipulator-X-Libero | FPGA design of the SmartFusion2 | Hardware |
The two computer repositories are checked out side by side. The Operator PC image
build reads the robot description and the DDS profile from the Robot PC checkout
(default path ../SmartManipulator-X-Robot-PC), see
Docker image and Compose.
Joint contract
The Operator PC, the Robot PC and the real hardware use the same joint names. They are
defined in smartmanipulator_x_description in the Robot PC repository; the Operator PC
only refers to them.
| Joint | Moveo axis | DYNAMIXEL ID (SmartFusion2) | MoveIt group | Controller |
|---|---|---|---|---|
j1_base |
J1 base | 1 | arm |
arm_controller |
j2_shoulder |
J2 shoulder | 2 and 3 (two mirrored motors) | arm |
arm_controller |
j3_elbow |
J3 elbow | 4 | arm |
arm_controller |
j4_forearm_roll |
J4 forearm roll | 5 | arm |
arm_controller |
j5_wrist |
J5 wrist | 6 | arm |
arm_controller |
gripper |
gripper servo | 7 | gripper |
gripper_controller |
The gripper linkage has mimic joints (gripper_idler_gear, gripper_pivot_*,
gripper_finger_*) that follow gripper; they are neither planned nor commanded.
Current status
- Operator PC (this repository): ROS 2 Jazzy image with MoveIt 2, pick_ik and RViz2;
move_groupand RViz2 start with one Compose command, joinsmx_net, plan with OMPL and execute through the Robot PC'sarm_controllerandgripper_controller, with the Robot PC running mock hardware on the same computer. - Robot model: generated from the BCN3D Moveo CAD in the Robot PC repository. Joint limits are still placeholders until measured on the real arm; the MoveIt joint limits of this repository are conservative placeholders as well.
- Real hardware: not reachable from the Operator PC yet — the Robot PC refuses
use_mock_hardware:=falseuntil its real-hardwareros2_controlpath is verified (see the Robot PC documentation). - Open items: Gazebo simulation on the Operator PC, measured joint limits and velocities, two-host operation over real Ethernet, orientation goals with a 5-DOF-aware IK setting.